
Advanced sensor fusion platform (INS-NV)
Programmable Inertial Navigation System Development Platform
Integrated solution combing Inertial Navigation System (INS), Attitude and Heading Reference System (AHRS), and Nvidia Jetson Compute Module. Delivering high performance development platform for machine vision algorithms and demanding guidance applications for alternative PNT.
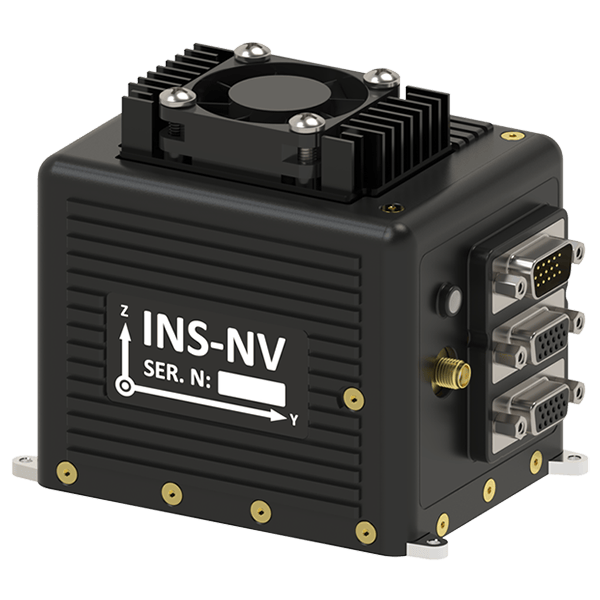
Inertial Labs INS-NV integrates Nvidia Jetson compute module and Inertial Labs INS to deliver a modular high-performance development platform to host demanding navigation algorithms.
Built as development platform, the INS-NV enables rapid integration and significantly reduce integration time and time-to-market for product requiring robust real-time navigation and sensor fusion system, including machine vision, autonomy guidance system and for other demanding APNT algorithms.
By leveraging Inertial Labs’ aiding data ecosystem, advance sensor fusion filters, calibration software, and state of-the-art navigation algorithms, the INS-NV delivers precise time, position, velocity, and attitude measurements and maintain accurate orientation in GNSS-denied environment.
Features
- Fully calibrated tactical-grade MEMS accel and gyros
- MIL-STD-810G compliant1
- Full-constellation GNSS receiver (GPS/ QZSS/ GLO/ GAL/ BDS/ NavIC)
- ASPN-compliant data interface (upon request)
- Embedded barometric altimeter
- Embedded in-flight magnetometers calibration
Benefits
- High performance in dynamic and statis conditions.
- Accurate orientation and navigation in GNSS-denied environment
- Expandable sensor fusion with external aiding sources
- Compatible with Commercial Off-The-Shelf cameras or Inertial Labs Sensor Modules
- Rapid integration and reduced time-to-market development
- Raw GNSS measurements and IMU data for post processing
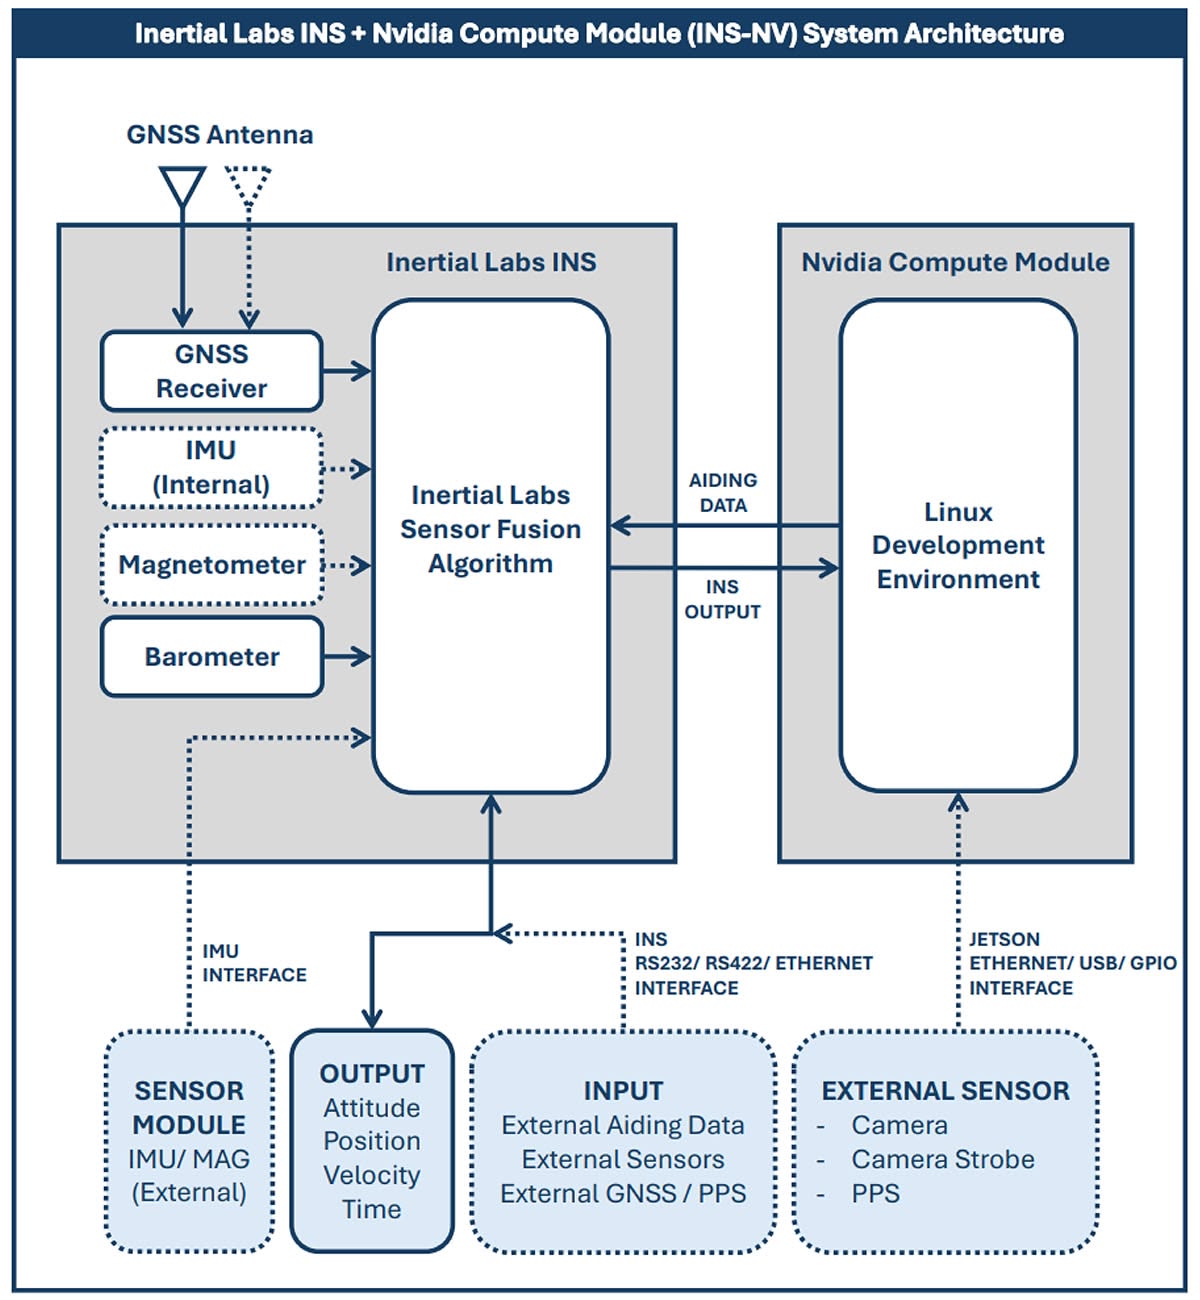
INS-NV System Architecture
INS-U Main Specifications
| Parameter | INS-U / INS-UOEM |
|---|---|
| Heading Accuracy | 0.6° static / 0.3° dynamic |
| Position Accuracy | 1cm (RTK) |
| Pitch & Roll Accuracy | 0.05° dynamic, 0.08° static |
| GNSS Constellations | BDS, GAL, GLO, GPS, QZSS |
| Corrections | DGPS, RTK, SBAS |
| Magnetometer | Embedded Mini-Fluxgate Magnetometer |
| Other Features | Static & Dynamic Pressure, Airspeed, Mach Number, True Angle of Attack (ADC) |
| Size (mm) |
INS-U: 82x40x26 INS-U-OEM: 65.0x37.2x19.9 |
| Weight (gram) |
INS-U: 200 INS-U-OEM: 100 |
Related Products
APNT Solutions
INS-NV
VINS
IRINS
IRINS-DM
Trademark Legal Notice: All product names, logos, and brands are the property of their respective owners. All company, product, and service names used in this document are for identification purposes only. Use of these names, logos, and brands does not imply endorsement. ABS, BeiDou, Cobham Limited, EdgeTech, Galileo, GLONASS, GPS, Hexagon, HYPACK, IMAGENEX, Kongsberg Seatex, LabVIEW, Livox, Norbit, NovAtel, NovAtel Inertial Explorer, Ouster, Qinsy, Quanergy, QZSS, R2Sonic, RIEGL, ROCK Robotic, ROS, Septentrio, Ship Motion Control SMC, Teledyne TSS, u-blox, Velodyne, WAASP, Waypoint.