
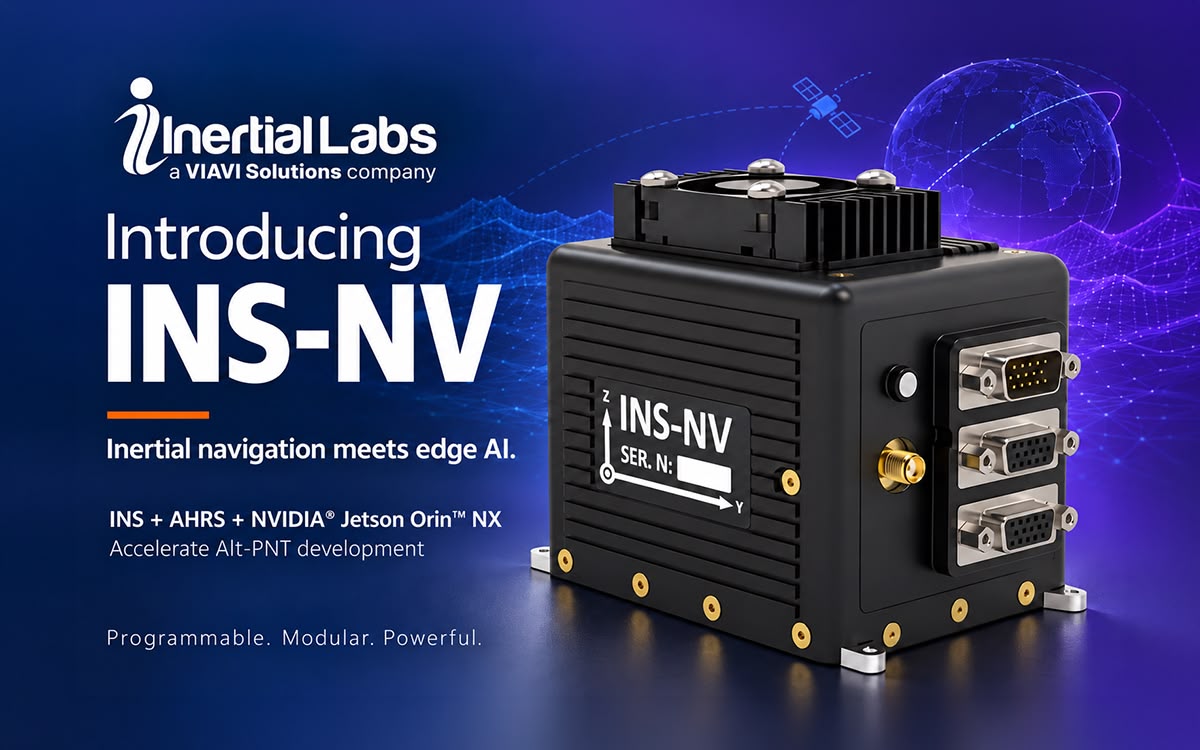
We’ve launched the INS-NV, a programmable Alt-PNT development platform that combines our inertial navigation system (INS) and AHRS technology with an NVIDIA Jetson Orin NX module.
It’s made for teams building visual navigation and machine vision algorithms for GNSS-denied environments. With a powerful edge AI processor on board, developers can run their own software next to the INS instead of spending months integrating the two.
Built for GNSS-denied and compromised environments
The INS-NV supports real-time navigation and sensor fusion where satellite signals can’t be trusted. It runs on our aiding data ecosystem, sensor fusion filters, calibration software and navigation algorithms, and delivers precise time, position, velocity and attitude.
What’s inside
The platform integrates fully calibrated tactical-grade MEMS accelerometers and gyroscopes, a barometric altimeter, magnetometers, and a full-constellation GNSS receiver covering GPS, QZSS, GLONASS, Galileo, BeiDou and NavIC.
Expandable by design
You can add Inertial Labs sensor modules and commercial off-the-shelf vision cameras as your project grows.
Why we built it
Jamie Marraccini, Vice President of Inertial Labs Products at VIAVI, explains that visual navigation depends on continuous data about a vehicle’s position, orientation and time. Most of these systems have lacked a high-end processor, so developers have had to put significant R&D time and budget into INS integration before they could even build a platform. The INS-NV removes that barrier. Teams can run their own visual navigation stacks alongside our INS and AHRS and bring advanced alternative navigation and PNT systems to the field faster.
Availability
The INS-NV is available now. MAVLink, ASPN, pntOS and MOSA-compliant variants are available on request. Contact our team to discuss your project.
Read the original announcement on VIAVI’s website: Inertial Labs, a VIAVI Solutions Company, Accelerates Complex Alt-PNT and Guidance Systems Design with Programmable INS Development Platform


