
Single Antenna GPS-Aided Inertial Navigation System (INS‑B)
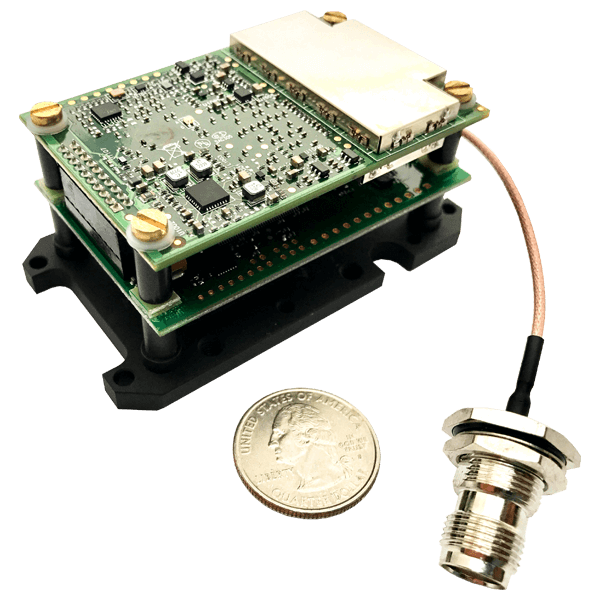
The INS-B is the baseline tactical-grade unit in the Inertial Labs INS family, built for integrators who need survey-quality position and orientation from one GNSS antenna. Inertial Labs, a VIAVI Solutions company, ships it in two forms: an IP67 aluminium enclosure and a 174-gram OEM board-level version for payload-constrained builds.

Where the INS-B earns its place
Position resolves to 1 cm + 1 ppm with RTK corrections, 2.5 cm under TerraStar-C PRO, and 5 mm in post-processing. When satellites drop out, the Tunnel Guide algorithm holds land-vehicle position drift to 0.2% of distance travelled — the reason the INS-B keeps turning up in mobile mapping rigs, UGV stacks and lightweight AGVs.
Sensor core
A tactical-grade IMU carries gyroscopes with 1 deg/hr in-run bias stability and angular random walk under 0.2 deg/√hr (0.08 optional), paired with accelerometers holding 0.005 mg in-run bias at the ±8 g range. Heading lands at 1° static, 0.1° dynamic, 0.03° post-processed. Pitch and roll: 0.05° static across the full temperature range, 0.03° dynamic.
Integration and receivers
Choose NovAtel OEM719, Septentrio mosaic-X5, or u-blox ZED-F9P / ZED-F9P-L5. Drivers exist for ROS, LabVIEW, Waypoint Inertial Explorer and QINSy. The unit talks directly to ArduPilot and PX4 flight controllers and emits AT_ITINS messages to the Cobham AVIATOR UAV 200. Odometer, wheel sensor, DMI, DVL, airspeed and wind-sensor aiding inputs are all accepted.
Build and environment
Qualified to MIL-STD-810G and MIL-STD-461F, rated IP67, operating from -40 to +75 °C. Draw is 2.5 W, or 3.5 W with the optional 64 GB logger. Enclosed unit: 120.5 × 53.2 × 49.3 mm, 220 g.
Key features & functionality
- Excellent accuracy in GPS-Denied environments
- Tactical-grade IMU
- Support: ROS, LabVIEW, Waypoint Inertial Explorer, QINSy
- GPS, GLONASS, GALILEO, BEIDOU, SBAS, DGPS, RTK supported signals
- High-performance GNSS receivers
- Compatibility with LiDARs (Velodyne, RIEGL, FARO) and optical cameras
- Odometer, Wheel sensor, Airspeed sensor, Wind sensor aiding data
- Advanced, extendable, embedded Kalman Filter based sensor fusion algorithms
- State-of-the-art algorithms for different dynamic motions of Vessels, Ships, Helicopters, UAV, UUV, UGV, AGV, ROV,
Gimbals and Land Vehicles - Implemented ZUPT, ZARUPT, Tunnel Guide, GNSS tracking angle features
- Full temperature calibration, compact design, MIL-STD-810G/DO-160E
- Full integration with ArduPilot platform
INS-B Main Specifications
| Parameter | INS-B | INS-B OEM |
|---|---|---|
| Heading Accurasy | 1° static / 0.1° dynamic | 1° static / 0.1° dynamic |
| Position Accuracy | 1cm (RTK), 2.5cm (PPP), 60cm (SBAS) | 1cm (RTK), 2.5cm (PPP), 60cm (SBAS) |
| Pitch & Roll Accuracy | 0.03° dynamic, 0.05° static | 0.03° dynamic, 0.05° static |
| GNSS Constellations | BDS, GAL, GLO, GPS, QZSS | BDS, GAL, GLO, GPS, QZSS |
| Corrections | DGPS, PPK, PPP, RTK, SBAS | DGPS, PPK, PPP, RTK, SBAS |
| Type of IMU | MEMS, Tactical-grade | MEMS, Tactical-grade |
| Magnetometer | External Magnetic Compass (optional) | External Magnetic Compass (optional) |
| Other Features | Tactical Grade IMU, Advanced, extendable, embedded Kalman Filter with sensor fusion algorithms | Tactical Grade IMU, Advanced, extendable, embedded Kalman Filter with sensor fusion algorithms |
| Size (mm) | 120.5 x 53.2 x 49.3 | 85.5 x 47.7 x 39.4 |
| Weight (gram) | 220 | 174 |
Related Products
Trademark Legal Notice: All product names, logos, and brands are the property of their respective owners. All company, product, and service names used in this document are for identification purposes only. Use of these names, logos, and brands does not imply endorsement. ABS, BeiDou, Cobham Limited, EdgeTech, Galileo, GLONASS, GPS, Hexagon, HYPACK, IMAGENEX, Kongsberg Seatex, LabVIEW, Livox, Norbit, NovAtel, NovAtel Inertial Explorer, Ouster, Qinsy, Quanergy, QZSS, R2Sonic, RIEGL, ROCK Robotic, ROS, Septentrio, Ship Motion Control SMC, Teledyne TSS, u-blox, Velodyne, WAASP, Waypoint.